
RS-001
Tacpose
UIST2025 Poster / IROS2026 Workshop
Exploring triaxial tactile sensors as a comfortable and easy-to-use approach for wearable continuous hand pose estimation.
Open Case FileArchive of selected research projects, personal projects, and events. Some are still work in progress. I thank everyone who has been involved in these projects and events, and I am excited to share them here.
UIST2025 Poster / IROS2026 Workshop
Exploring triaxial tactile sensors as a comfortable and easy-to-use approach for wearable continuous hand pose estimation.
Open Case File
Best Session Presentation Award @ CACS2025
Repurposing an off-the-shelf Bluetooth pin microphone for low-cost, easily integrated contact sensing in HCI & robotics applications.
Open Case File
HRI2025 Workshop
Created a teleoperation interface that enhances user awareness through real-time soft robot finger shape visualization in extended reality (XR).
Open Case File
CVM2026 Technical Brief
Made a flow matching-based pipeline that generates realistic, text prompt-guided texture map while strictly respecting an input Digital Elevation Map (DEM).
Open Case File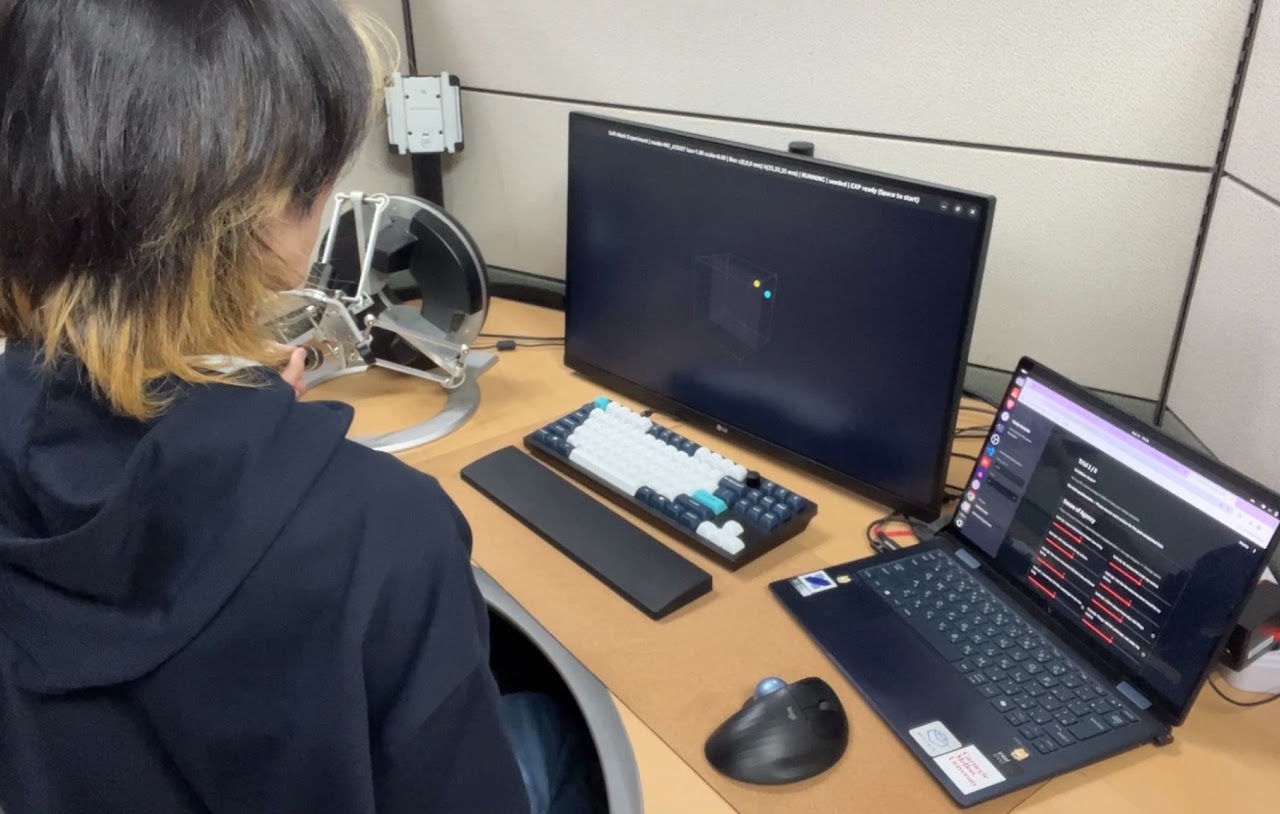
VSR Project @ KAIST
Explored SoftNash, an entropy-regularized Nash game formulation for non-fighting virtual fixtures in teleoperation.
Open Case File
Robotics Passion Project
Created potentially the smallest robot arm using self-made daisy chain motor driver modules.
Open Case File
Winning Project @ GDGoC Bridge Hackathon 2026
Developed a chrome extension that modifies web UI based on a given persona.
Open Case File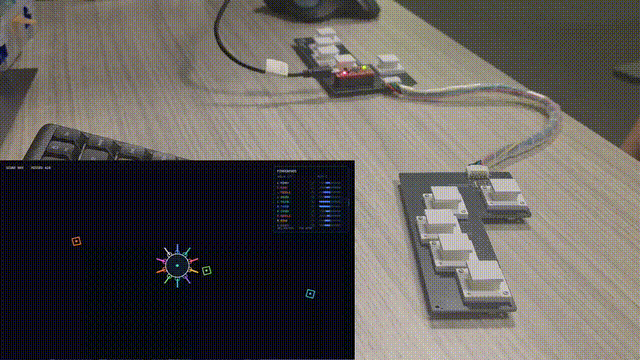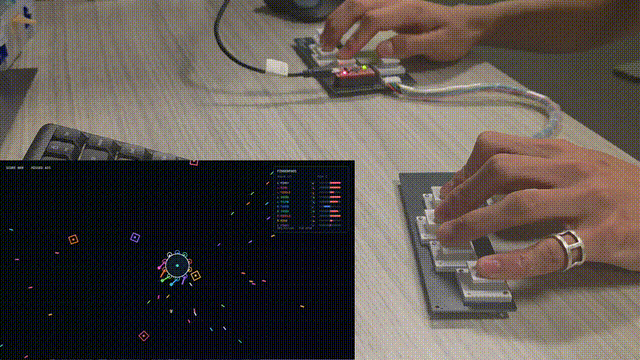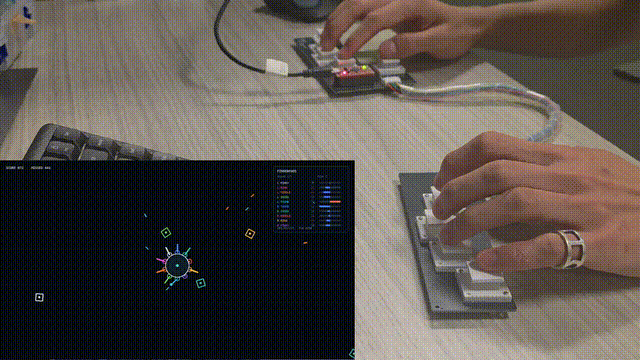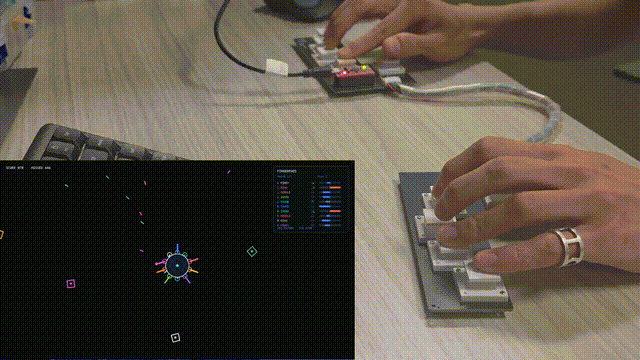
Interactive Hardware Prototype
Built a tactile controller and game prototype that links physical input hardware with responsive on-screen interaction.
Open Case File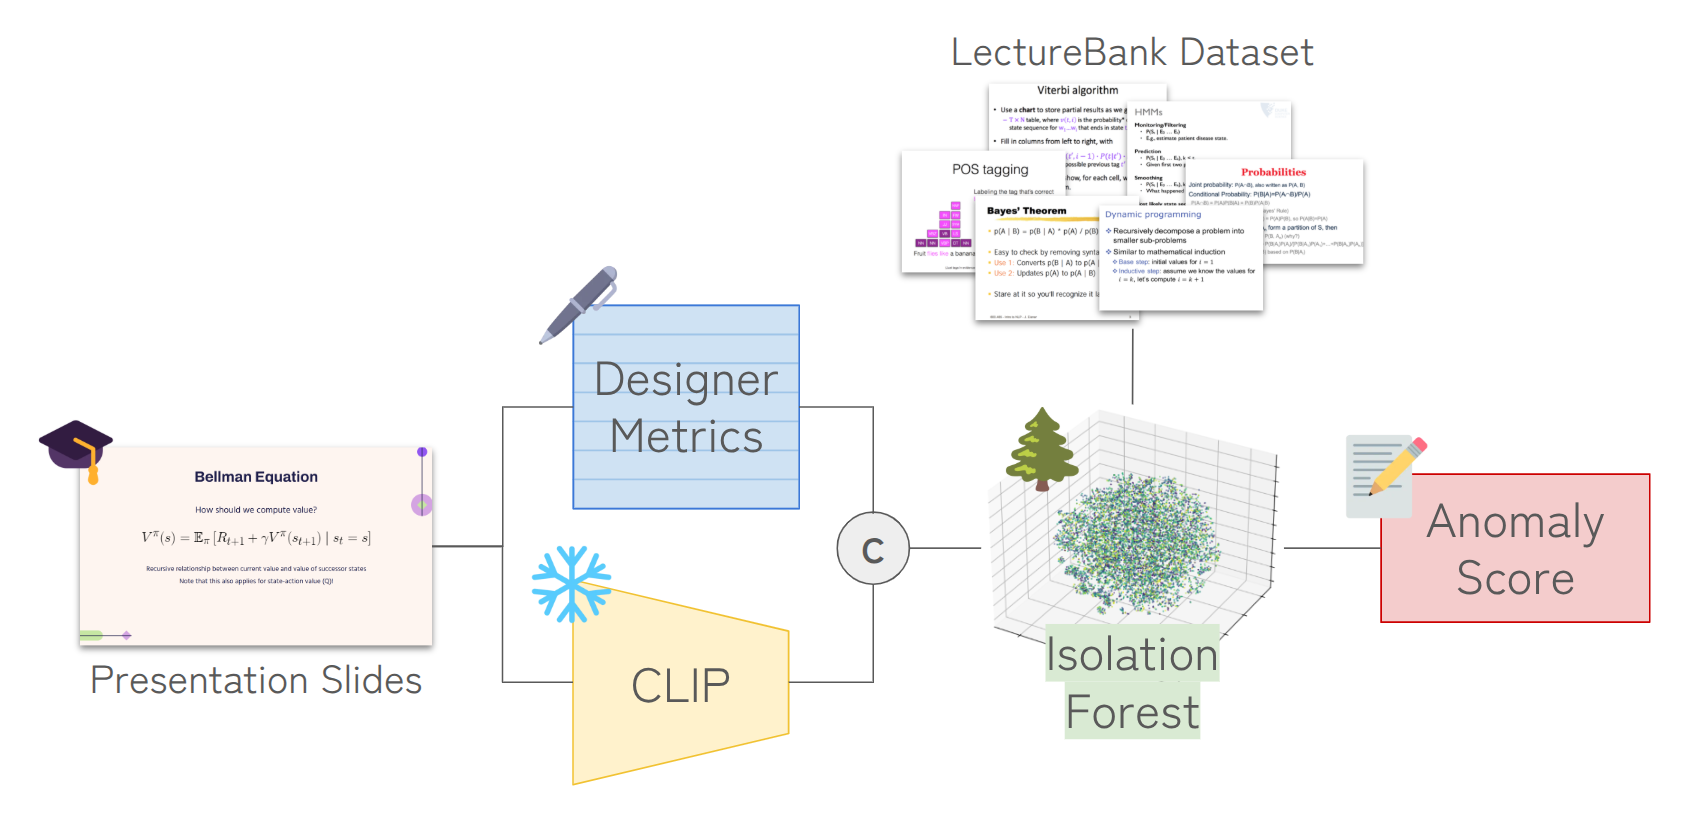
Presentation Slidedeck Analysis
Created an unsupervised slide quality assessment pipeline that combines seven expert inspired visual design metrics with CLIP-ViT embeddings, using Isolation Forest-based anomaly scoring to evalute presentation slides.
Open Case File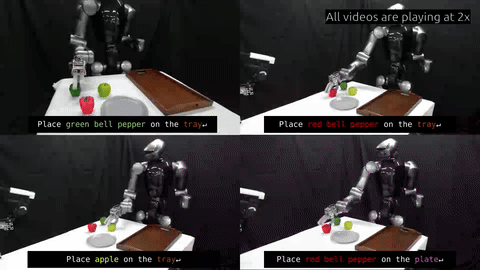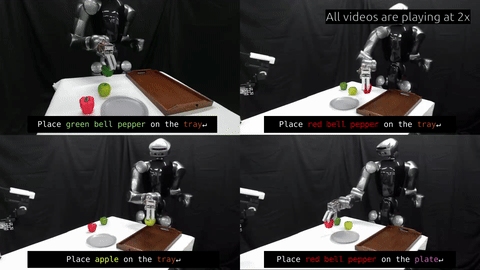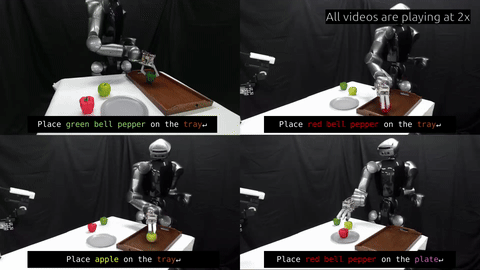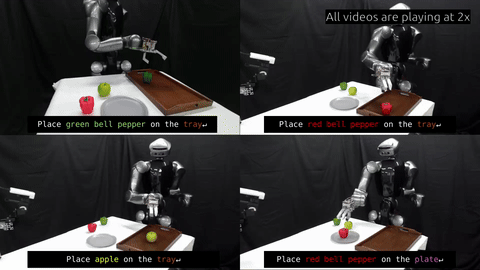
Robot Learning Project @ Tokyo Robotics
Deployed a Vision-language-Action (VLA) model onto a humanoid robot. It can now perform pick and place tasks from natural language instructions.
Open Case File
google developer group on campus
Under GDGoC, we hosted a hands-on workshop on game development with Unity. After introducing the basic concepts of Unity, we recreated Flappy Bird with the audience.

Kuma Lab
Core members of Kuma Lab hosted a workshop on "Robotic Art", where we explored how the two fields that seem to be far apart: Robotics and Art, can go together to form an interesting topic of research.

Kuma Lab X GDGOC
Kuma Lab and GDGoC collaborated to host a hands-on workshop on AI. We introduced the basic concepts of AI, through its applications in 3 fields: Computer Vision, Robot Learning, and 3D Reconstruction.